What I built
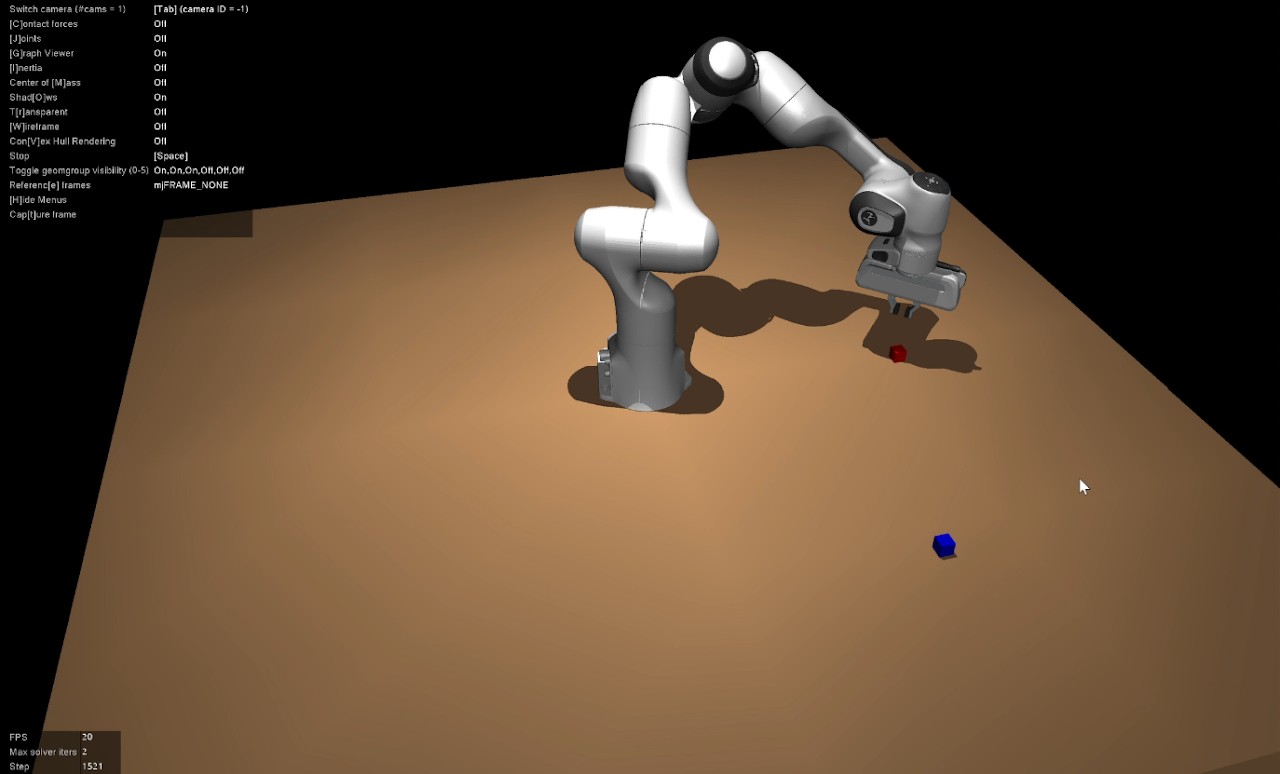
For MENG 405, I implemented the full control pipeline for a simulated Franka Emika Panda arm doing a pick-and-place sequence.
- Inverse kinematics is computed numerically using the Jacobian pseudoinverse method and an SE(3) error twist.
- Trajectory generation times each motion with quintic polynomial scaling for smooth accelerations.
- Torque-level control runs through a PD-plus-inverse-dynamics controller that uses the arm's live mass matrix and bias forces for accurate torque commands.
The robot picks up a randomly placed cube and places it at a second randomized target, tracking position and orientation error at each stage of the motion.
Videos of the full sequence are at the bottom of the page.