Project goal
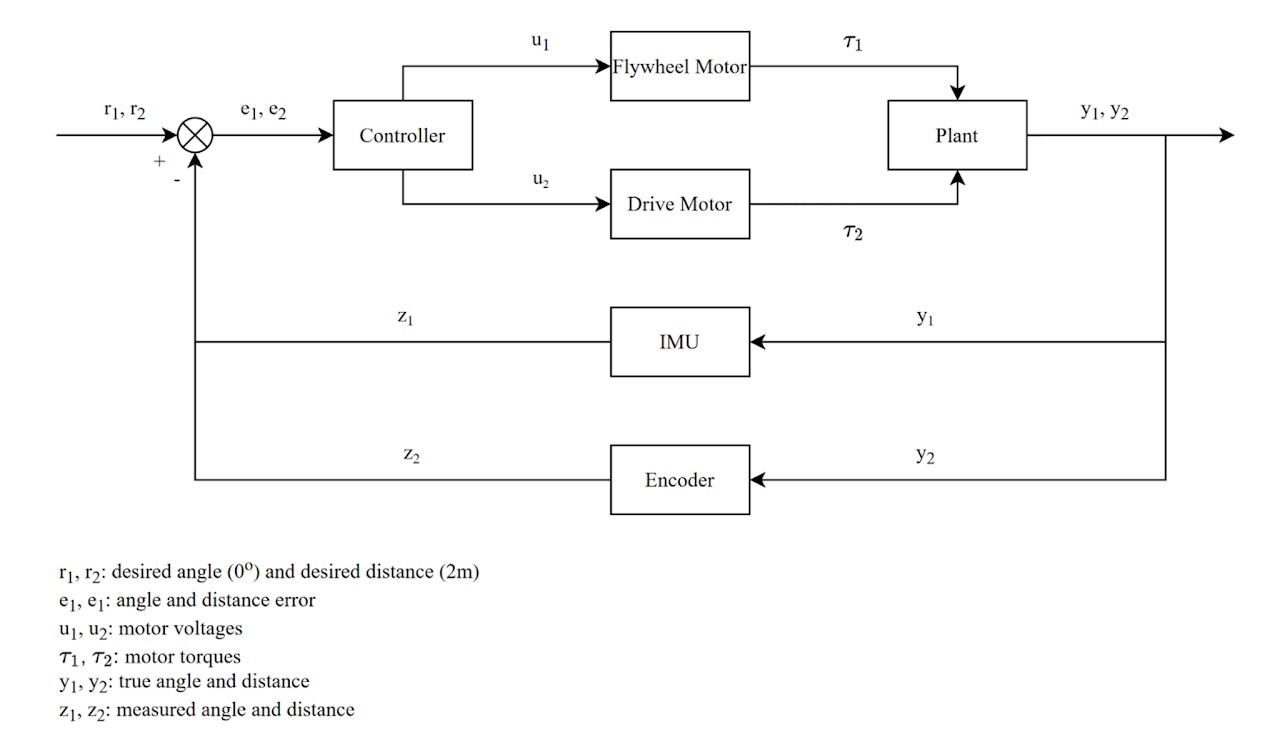
For MENG 389, we were tasked with designing and simulating a self-balancing, self-driving motorcycle that stays stable using a reaction flywheel and moves in a controlled way using drive motors. The goal was to combine classical control techniques with mechatronic systems for autonomous stability and motion.
Specifications
- Dual PID controller for flywheel stabilization and velocity regulation.
- 9-axis IMU.
- Arduino Nano 33 IoT, SAMD21 microcontroller.
Key takeaways
- Stable under payload variations and external disturbances, with less than 5% overshoot and under 2 s settling time.
- Hands-on practice bridging mechanical design and control theory.
- A stronger feel for feedback systems, system dynamics, and controller tuning.
Skills used
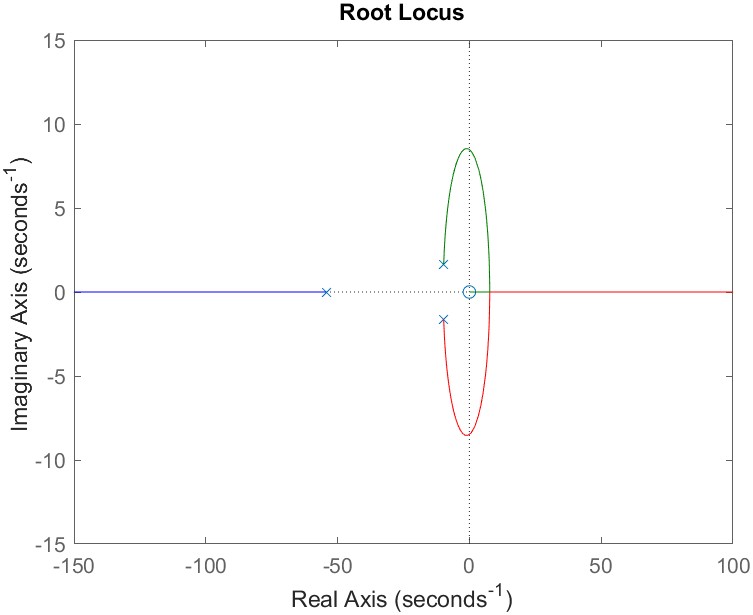
- Control systems design (PID tuning, stability analysis, root locus analysis)
- MATLAB/Simulink modeling and simulation
- Mechanical dynamics and transfer function modeling
- Sensor integration (IMU/encoder) and real-time feedback control
- Embedded systems and hardware-oriented control logic