Project goal
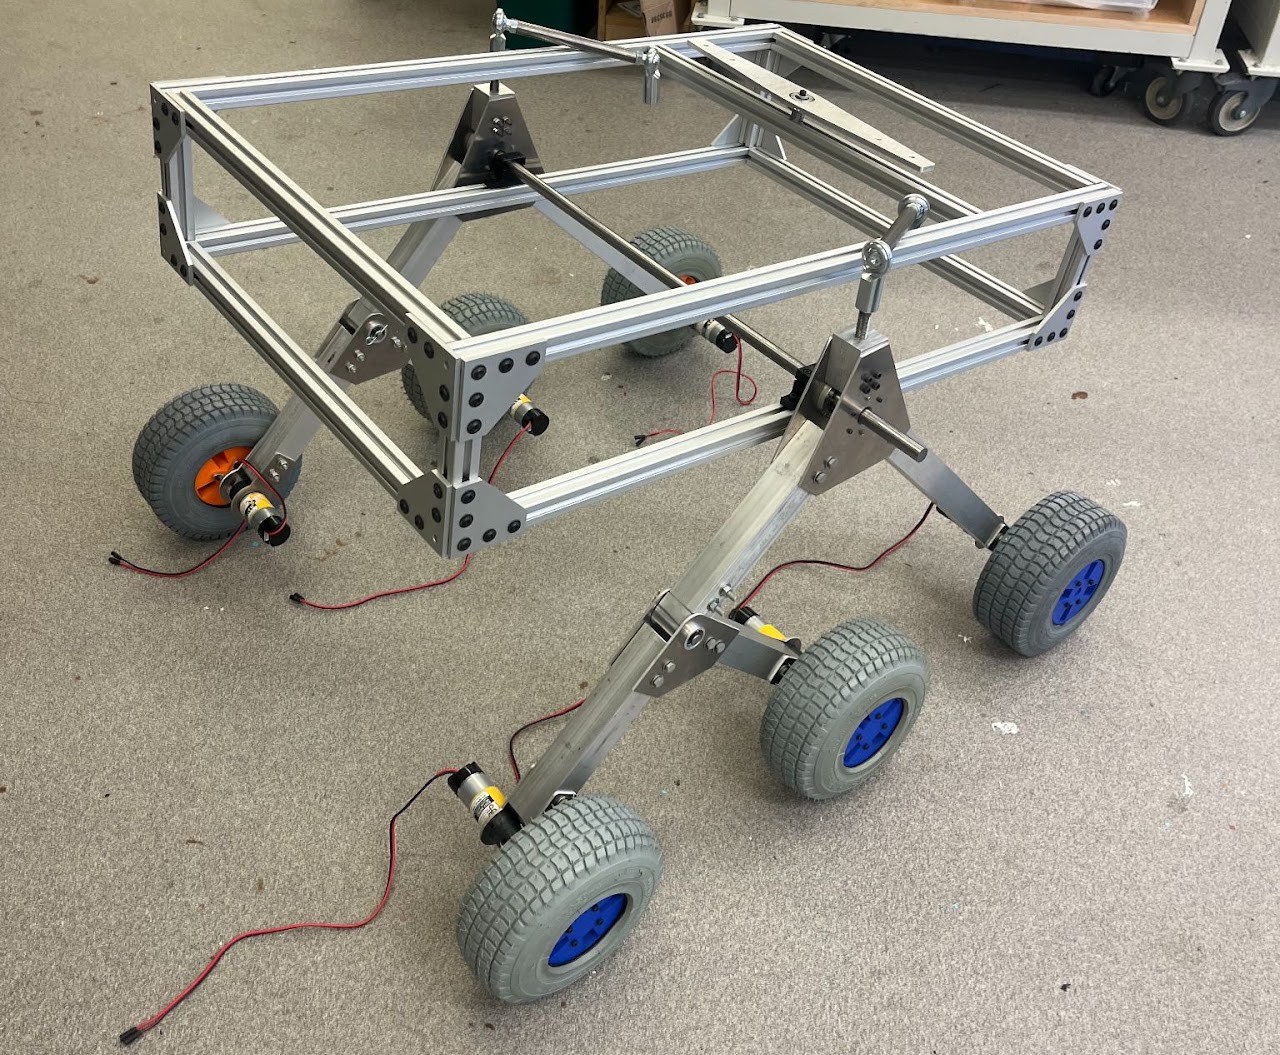
Yale Exploration Rover aims to build a competition-ready autonomous rover, complete with a science mission payload, to compete in the University Rover Challenge 2025. Last semester I took on the Drives Subteam Lead role, leading a team of eight students in the development of the rocker-bogie suspension, propulsion system, and chassis for Yale's competition rover.
Results
- Designed and assembled a rocker-bogie suspension system.
- Selected the 5203 Series Yellow Jacket planetary gear motor with a 26.9:1 gear ratio to meet the obstacle requirement.
- Built the chassis from T-slot framing for modularity.
Skills used
- CAD (Onshape)
- Project management
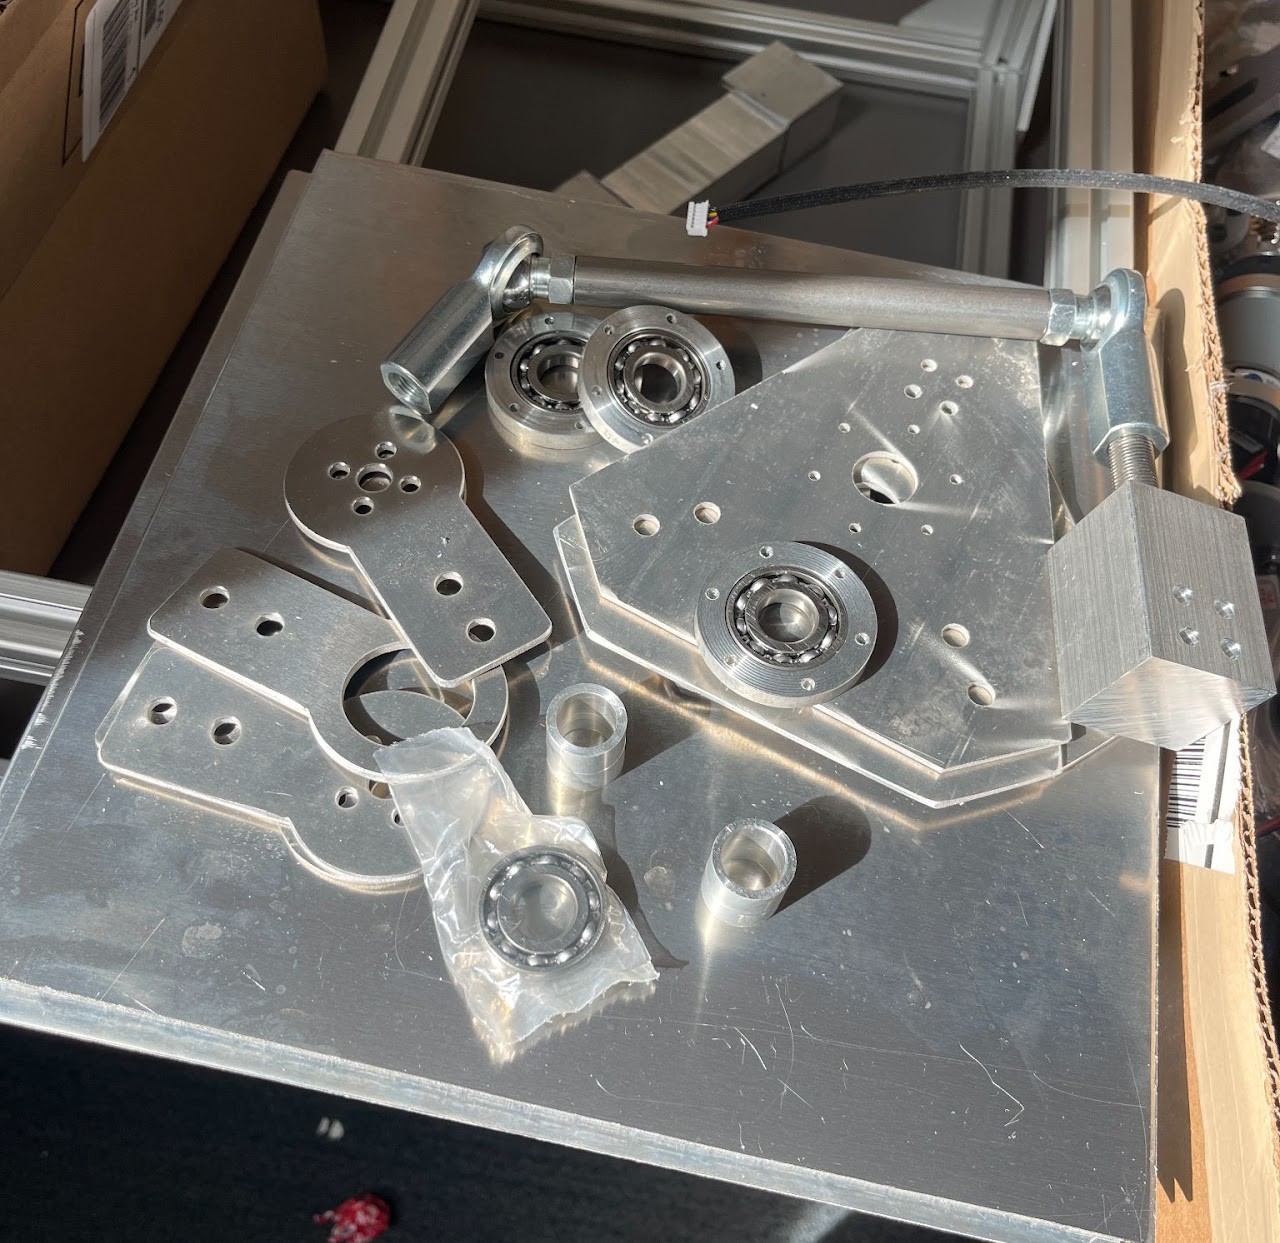
- Design for manufacturing
- Dynamic and static analysis (MATLAB)
- Motor analysis