Background
In April 2025, I joined the Faboratory at Yale University, a research lab focused on advancing the design and functionality of soft robots, which are robots made from compliant, flexible materials.
Beginning in the spring of my junior year, I began working under PhD candidate Caitlin Le to investigate how the mechanical properties of soft materials influence the burrowing forces exerted by granular media, such as dirt or sand, on a soft-bodied burrowing robot.
Project goal
Characterize the relationships between intruder (the object doing the burrowing) properties, such as elasticity or the presence of a rigid core, and the burrowing force the intruder experiences. Then use that data to move forward in the development of a burrowing robot.
What I did
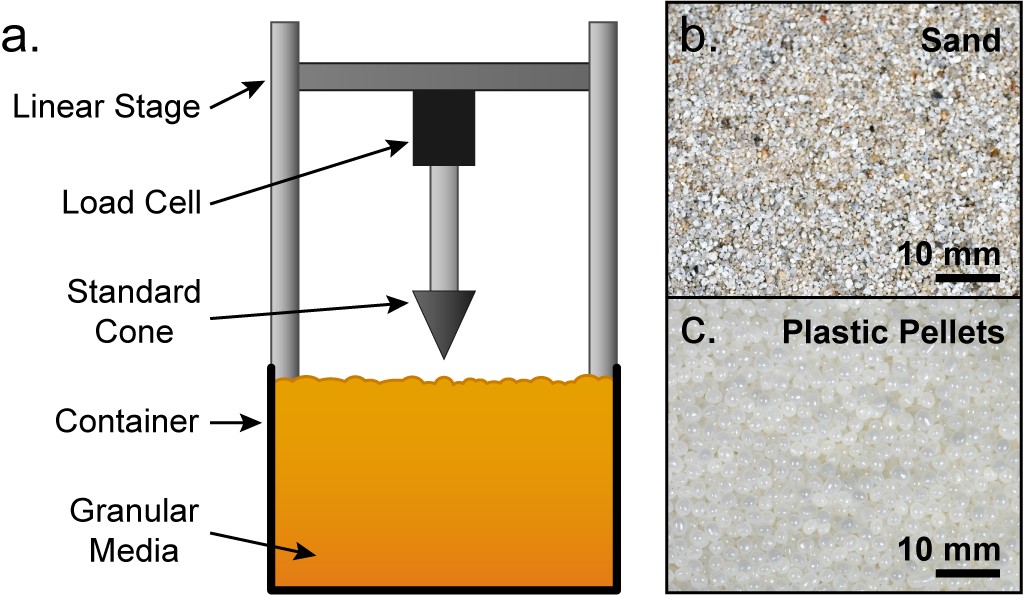
- Designed and fabricated a custom mechanical test apparatus around an Instron 3345 load frame to replicate subsurface conditions and measure burrowing forces.
- Ran 60+ cone penetrometer tests across chamber geometries and granular densities to characterize how materials and mechanisms interact.
- Fabricated silicone-based test intruders with controlled material properties.
Results
The group's paper, Common Ground: Standardizing Granular Media Characteristics for Burrowing Robots, is published on IEEE Xplore, and it was also submitted to IEEE RoboSoft. PDF copy from the Faboratory.